The subsystems and R&D work developed by our team that make up our vehicles.
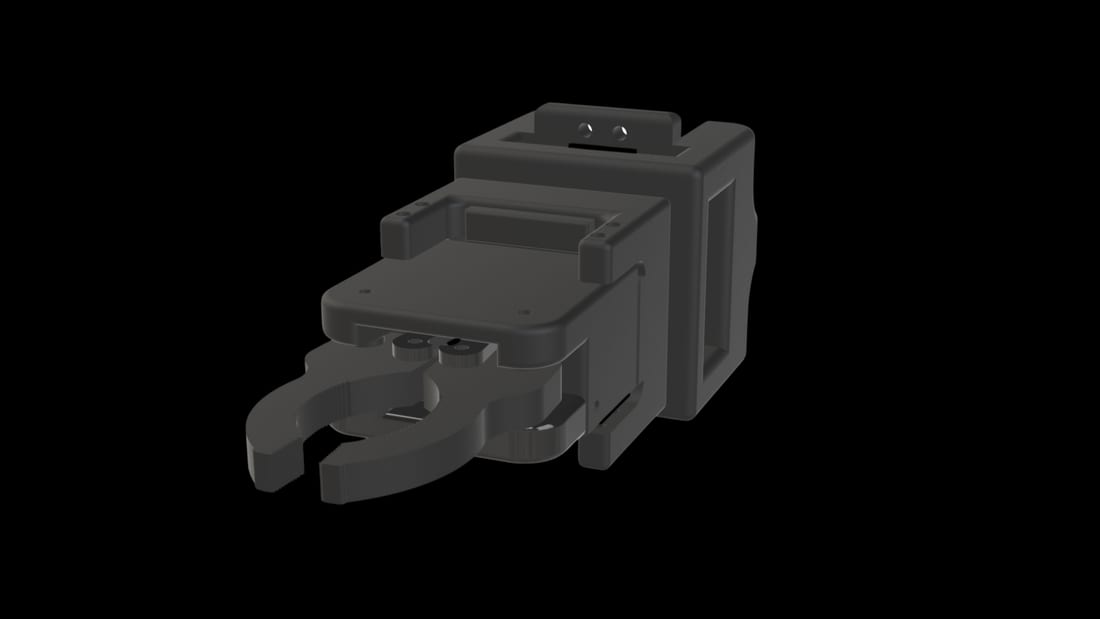
A robotic arm with rotational and curved motion in 3 axes; its design, manufacturing, hardware and software belong entirely to the team.
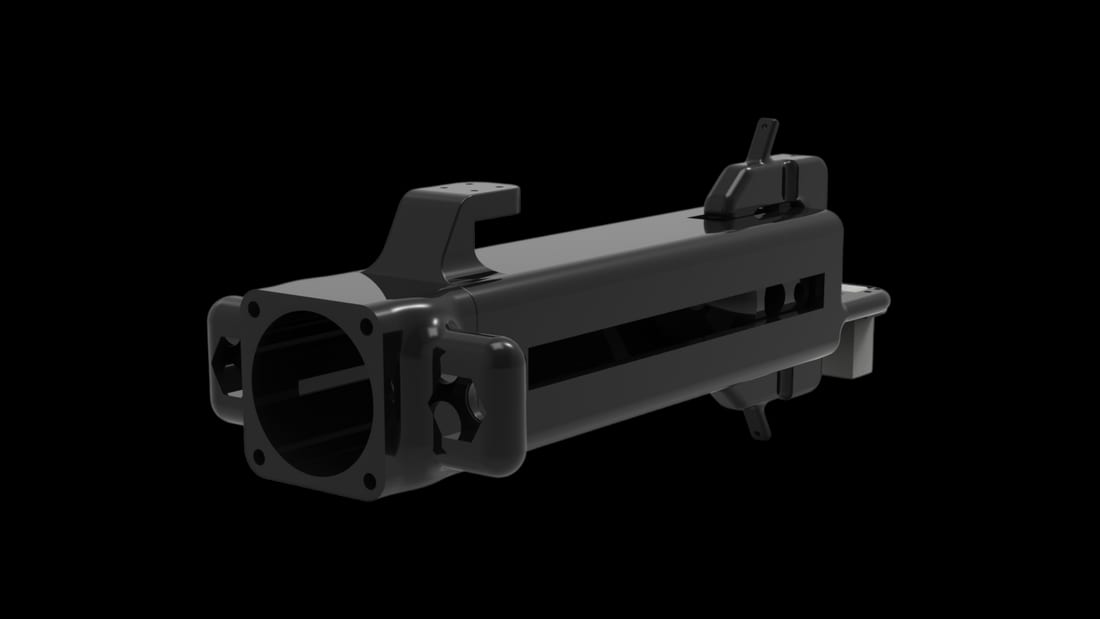
A system based entirely on mechanical principles — no pneumatics or igniters — developed for defense and reconnaissance purposes.
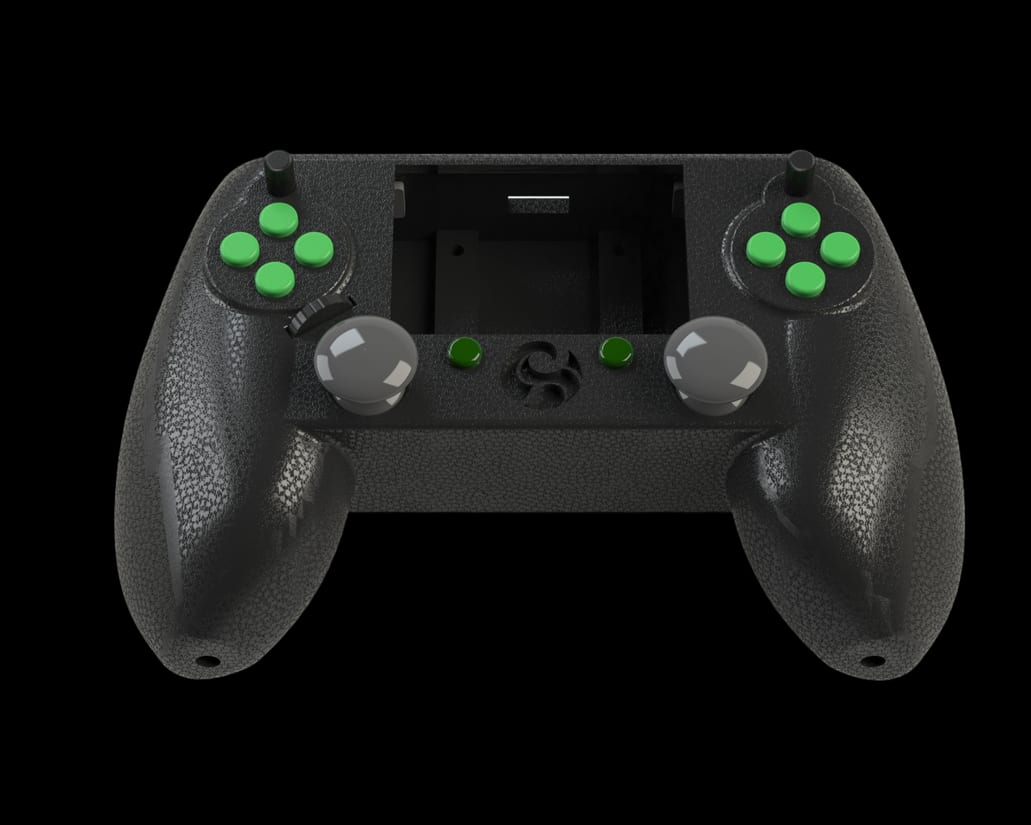
A fully team-built ROV controller providing manual control, parameter monitoring and mode switching.
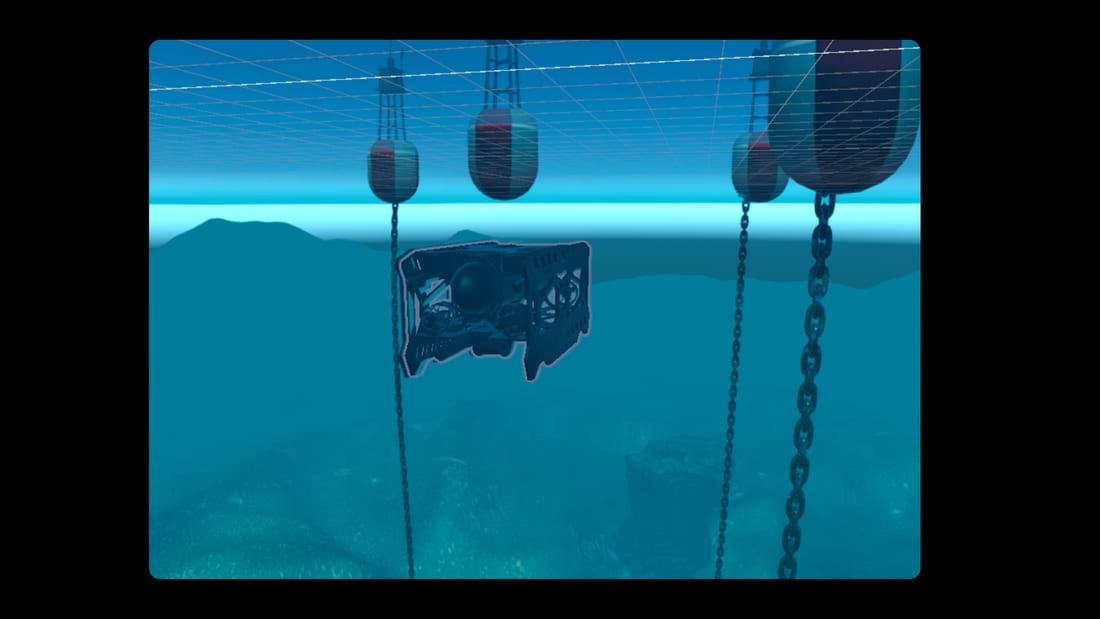
An underwater simulation built on Unity Engine; autonomous driving, pool scanning and vision tests run on a computer.
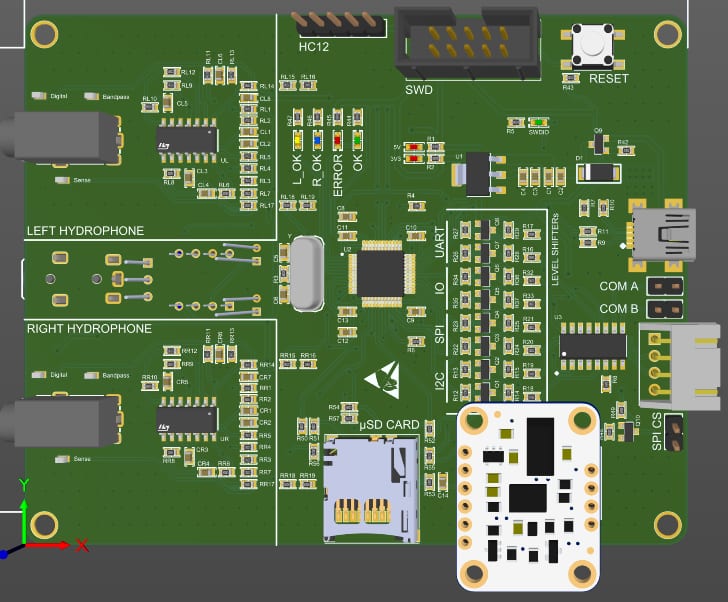
Detects underwater acoustic signals for localization and communication; performs direction finding with multiple hydrophones.
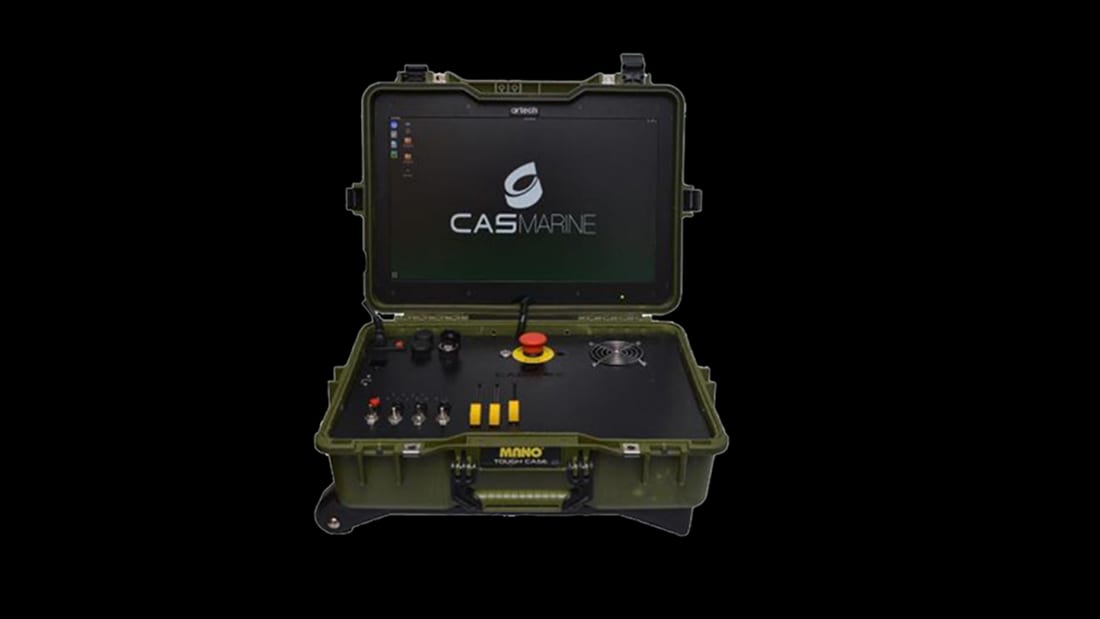
The processing unit where vehicle data is interpreted and presented; shows depth, pressure, camera and battery status in one interface.
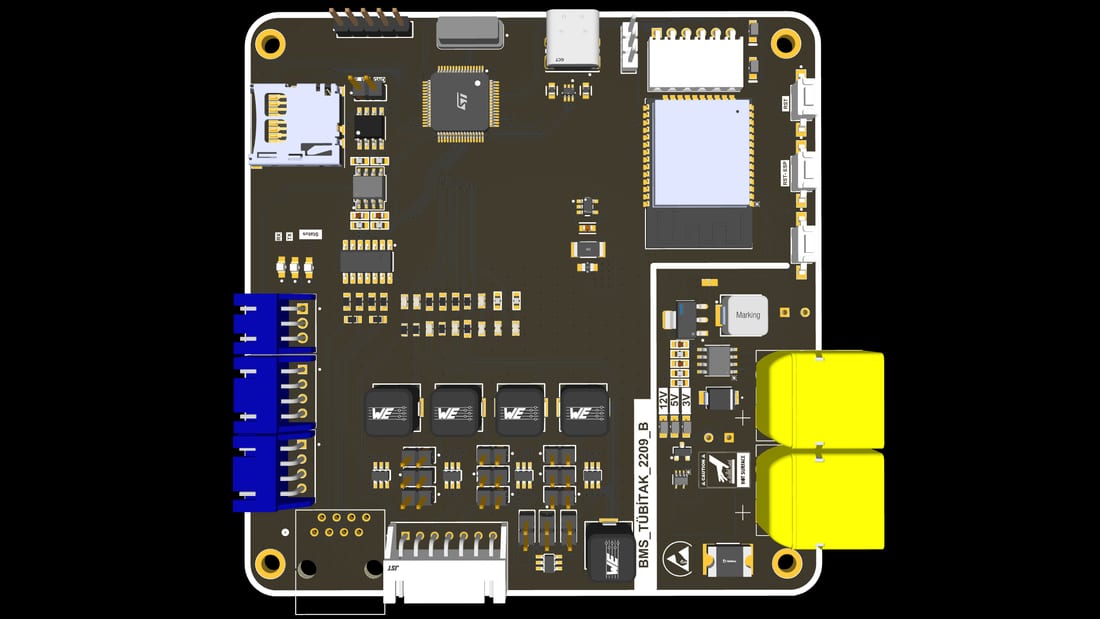
A control board that balances voltage differences between cells to keep the system healthy and efficient, with numerous protection circuits.